Robotics
Delivery Drone
A polished multipurpose drone designed to carry various payloads including thermal or regular cameras with gimbal. The goal is to create a drone that is both capable and purpose-flexible, as most commercial drones like DJI models are limited to single-purpose tasks.
View on GitHub ↗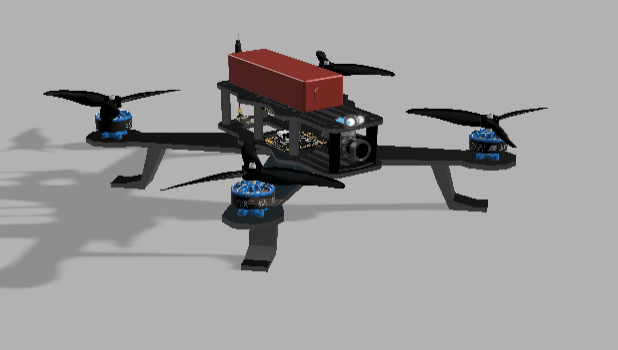
Explore the CAD model
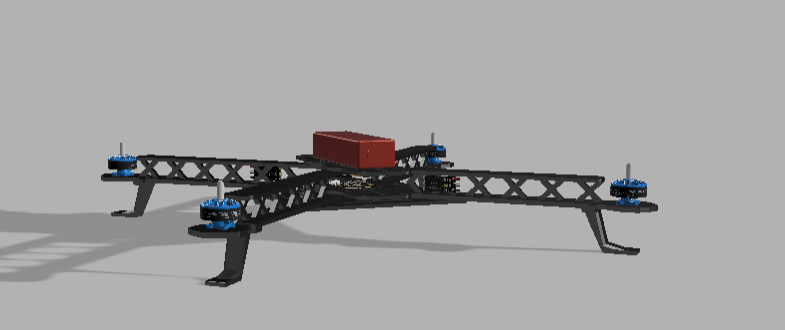
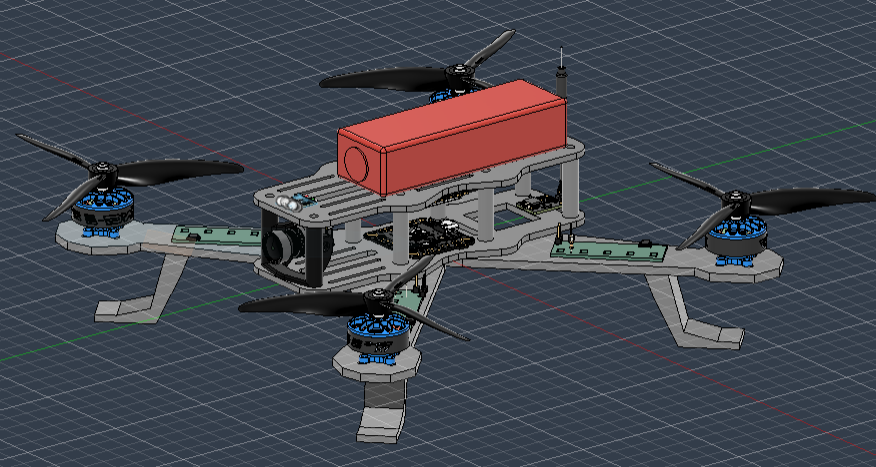
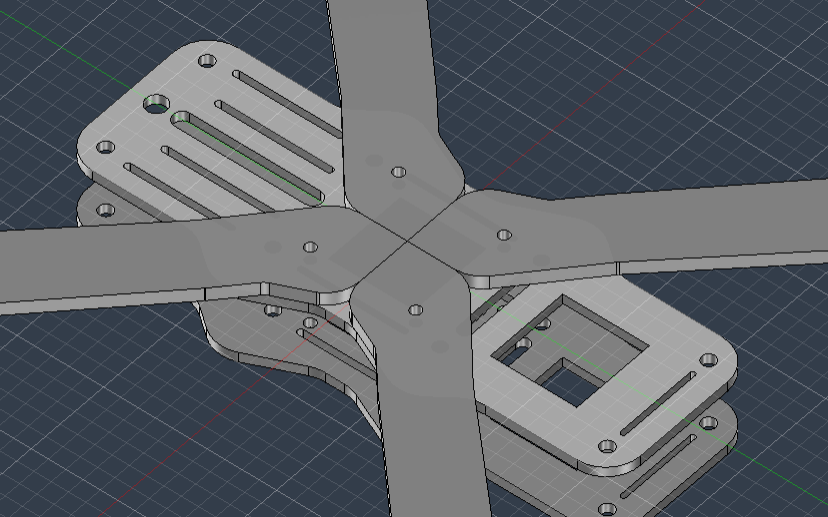
Delivery drone assemblyLoads on request. Drag to rotate; scroll or pinch to zoom.
Converted from the project CAD. Colours are simplified; this is design geometry rather than a scan of the finished build.
My interest in drones sparked in Grade 4 when I saw a DJI Phantom used for photography at a welcoming parade in Toronto. I've been intrigued by drones and their applications ever since. However, I find it frustrating that companies commercialize drones for single purposes. There are merits to creating drones that can handle multiple tasks such as FPV flying combined with casual photography to reduce consumer waste.
Due to increasing traffic congestion in cities, I aim to prototype a delivery drone that could eventually be scaled for autonomous delivery of everyday essentials. The drone will be medium to large sized (250-400mm or 400+mm), featuring CAN bus-capable flight controllers like the Pixhawk 6C Mini, GNSS systems, and a 3D-printed PETG frame.
Key features include: return-to-home, obstacle avoidance, autonomous flight-and-follow, autonomous address-based package delivery, and a DJI Dock-like auto-landing system. This project heavily leverages CAD design and 3D printing to create functional components with solid attachment points for payloads, including string-based attachment and package release mechanisms.
This is an excellent learning opportunity to develop skills in CAD analysis, functional 3D printing, embedded systems, and autonomous flight algorithms. Check the JOURNAL.md file on GitHub to follow the entire engineering and build process.
Images
Select an image to view full size.